Start Building With Omniverse
NVIDIA Omniverse libraries, part of NVIDIA Agent Toolkit, bring GPU-accelerated simulation and supporting tools to developers and AI agents building physical AI. Integrate NVIDIA RTX™ sensor simulation, physics, and simulation-ready asset validation into existing OpenUSD applications to build, test, and refine virtual worlds. Combine these capabilities with your existing tools and libraries to fit your workflow.
Fastest ways to start:

Libraries
Explore Omniverse libraries for application integration.

Agent Skills
Run an AI agent skill for a defined workflow.

Blueprints
Start from a blueprint for a complete physical AI workflow.

Samples
Explore experimental examples combining Omniverse libraries.
Omniverse AI Agent Skills
Use NVIDIA-verified skills to guide bounded agent workflows for OpenUSD, simulation-ready asset prep, synthetic data, neural reconstruction, viewer creation, and scene optimization, with human review at the decision points.
CAD to SimReady
Convert CAD assets into SimReady USD with geometry, materials, and physics for downstream workflows.
Best for: Turning CAD or source assets into reviewable USD outputs for simulation pipelines.
Defect Image Generation
Generate anomaly examples and evaluate models for AOI inspection use cases.
Best for: PCBA, metal surface, or glass inspection data workflows.
Neural Reconstruction
Reconstruct real-world driving scenes and generate variations for AV training.
Best for: Camera, lidar, radar, or stereo reconstruction workflows for AV and robotics datasets.
Realtime Viewer
Inspect OpenUSD scenes with a library-native viewer built from Omniverse tools.
Best for: Creating reviewable OpenUSD viewers without modifying source USD assets.
Video Data Augmentation
Augment and enrich simulation data for training physical AI models.
Best for: Enriching and labeling video datasets for physical AI model development.
USD Performance Tuning
Profile and tune large digital twin scenes for runtime simulation performance.
Best for: Diagnosing and improving large USD scenes before runtime or simulation use.
Omniverse Libraries for Simulation
Extend existing applications and workflows with simulation libraries that agents and developers can use.
Explore Omniverse Libraries on GitHub
ovphysx
Open source, USD-native physics library for scalable robotics and digital twin simulation.
Best for: Loading USD scenes, stepping physics, cloning environments, and exchanging simulation data through tensors.
ovrtx
GPU-accelerated rendering and sensor simulation libraries built on NVIDIA RTX.
Best for: Adding RTX rendering and sensor simulation to your existing simulator or 3D application.
ovstorage
Backend-neutral APIs to read, write, list, and access asset data across local and cloud storage.
Best for: Giving teams, agents, and tools a consistent way to access and route asset data across storage backends.
ovstage
Shared, GPU-capable scene data layer for high-performance simulation and visualization workflows.
Best for: Sharing scene data across compatible Omniverse libraries and accessing it through C, Python, and tensor interfaces.
ovnewton
Open source wrapper library that builds a Newton physics model from USD scene populated into ovstage.
Best for: GPU-accelerated physics for roboticists and simulation researchers with differentiability, user extensibility, and scale.
ovui
Python UI library for app interfaces, interaction tests, and CI screenshot checks.
Best for: Creating local tools, inspectors, and review apps around USD workflows.
ovstream
Stream rendered frames, audio, messages, and user input between GPU applications and interactive clients.
Best for: Delivering rendered or interactive output from tools such as ovrtx to local or browser clients.
OpenUSD and SimReady Content Libraries
Build and manage simulation-ready 3D content with OpenUSD frameworks, SimReady libraries, and conversion, validation, and optimization tools.
OpenUSD
Open source framework and standard for interoperable 3D data, SimReady assets, and agentic workflows.
Best for: Building interoperable 3D data workflows that can support simulation-ready content and agent-reviewed pipelines.
BReps
Support CAD geometry in OpenUSD.
Best for: Using exact and editable CAD geometry in OpenUSD pipelines.
mujoco-usd-converter
Convert MuJoCo models into OpenUSD for robotics simulation workflows.
Best for: Moving MuJoCo robot or simulation assets into OpenUSD for visualization, inspection, and targeted simulation workflows.
SimReady Central Library
Ungated library of SimReady assets on Hugging Face for developers to leverage and manufacturers to distribute.
Best for: Finding and combining simulation-ready assets to build physical AI training environments and AI factory digital twins.
SimReady Foundation
Framework and pipeline for creating and validating simulation-ready assets.
Best for: Understanding asset requirements, profiles, and validation targets for supported simulation workflows.
urdf-usd-converter
Convert URDF robot assets into OpenUSD for robotics simulation.
Best for: Preparing URDF robots for OpenUSD review and Newton-oriented simulation workflows.
usd-content-agents
Use agents to prepare simulation-ready OpenUSD assets.
Best for: Creating geometry, assigning materials, generating textures, adding physics and joints, and validating results.
usd-validation-nvidia
Validate OpenUSD assets against NVIDIA and core USD checks.
Best for: Adding repeatable USD validation checks to local tools, CI, or agent-reviewed pipelines.
usd-convert-cad
Convert supported CAD formats to OpenUSD with the Omniverse CAD Converter.
Best for: Bringing engineering CAD assets into USD workflows.
usd-convert-gsplat
Convert Gaussian splat data into OpenUSD for simulation and rendering.
Best for: Bringing .ply or .spz Gaussian splat data into OpenUSD workflows.
usd-exchange
SDK and authoring skills for creating and exchanging OpenUSD content.
Best for: Authoring USD content or mapping application data into OpenUSD.
usd-optimize
Optimize OpenUSD content for performance and memory.
Best for: Reducing scene complexity, memory use, or runtime cost in OpenUSD applications and pipelines.
usd-search
Enable natural language search and reasoning across OpenUSD content.
Best for: Finding assets, prims, dependencies, or similar content across large USD libraries.
usd-convert-asset
Convert common 3D asset formats to the interoperable OpenUSD format.
Best for: Scriptable asset ingestion into OpenUSD-based workflows.
Simulation Libraries for Physical AI
These foundational simulation libraries power advanced physics, reconstruction, and AI modeling workflows. Use them directly when you need lower-level control, or through Omniverse tools and skills when building agentic physical AI workflows.
Newton Physics
An open source, extensible physics engine built on NVIDIA Warp and OpenUSD.
NuRec
APIs, libraries, and datasets for 3D Gaussian-based neural simulation from real-world data.
PhysX
Open source multi-physics SDK for scalable robotics simulation and modeling.
PhysicsNeMo
A CUDA-X™ library and open source Python framework for building, training, and fine-tuning AI physics models at scale.
NVIDIA Warp
Open source Python framework and CUDA-X library that delivers GPU acceleration for computational physics, AI, and optimization workflows.
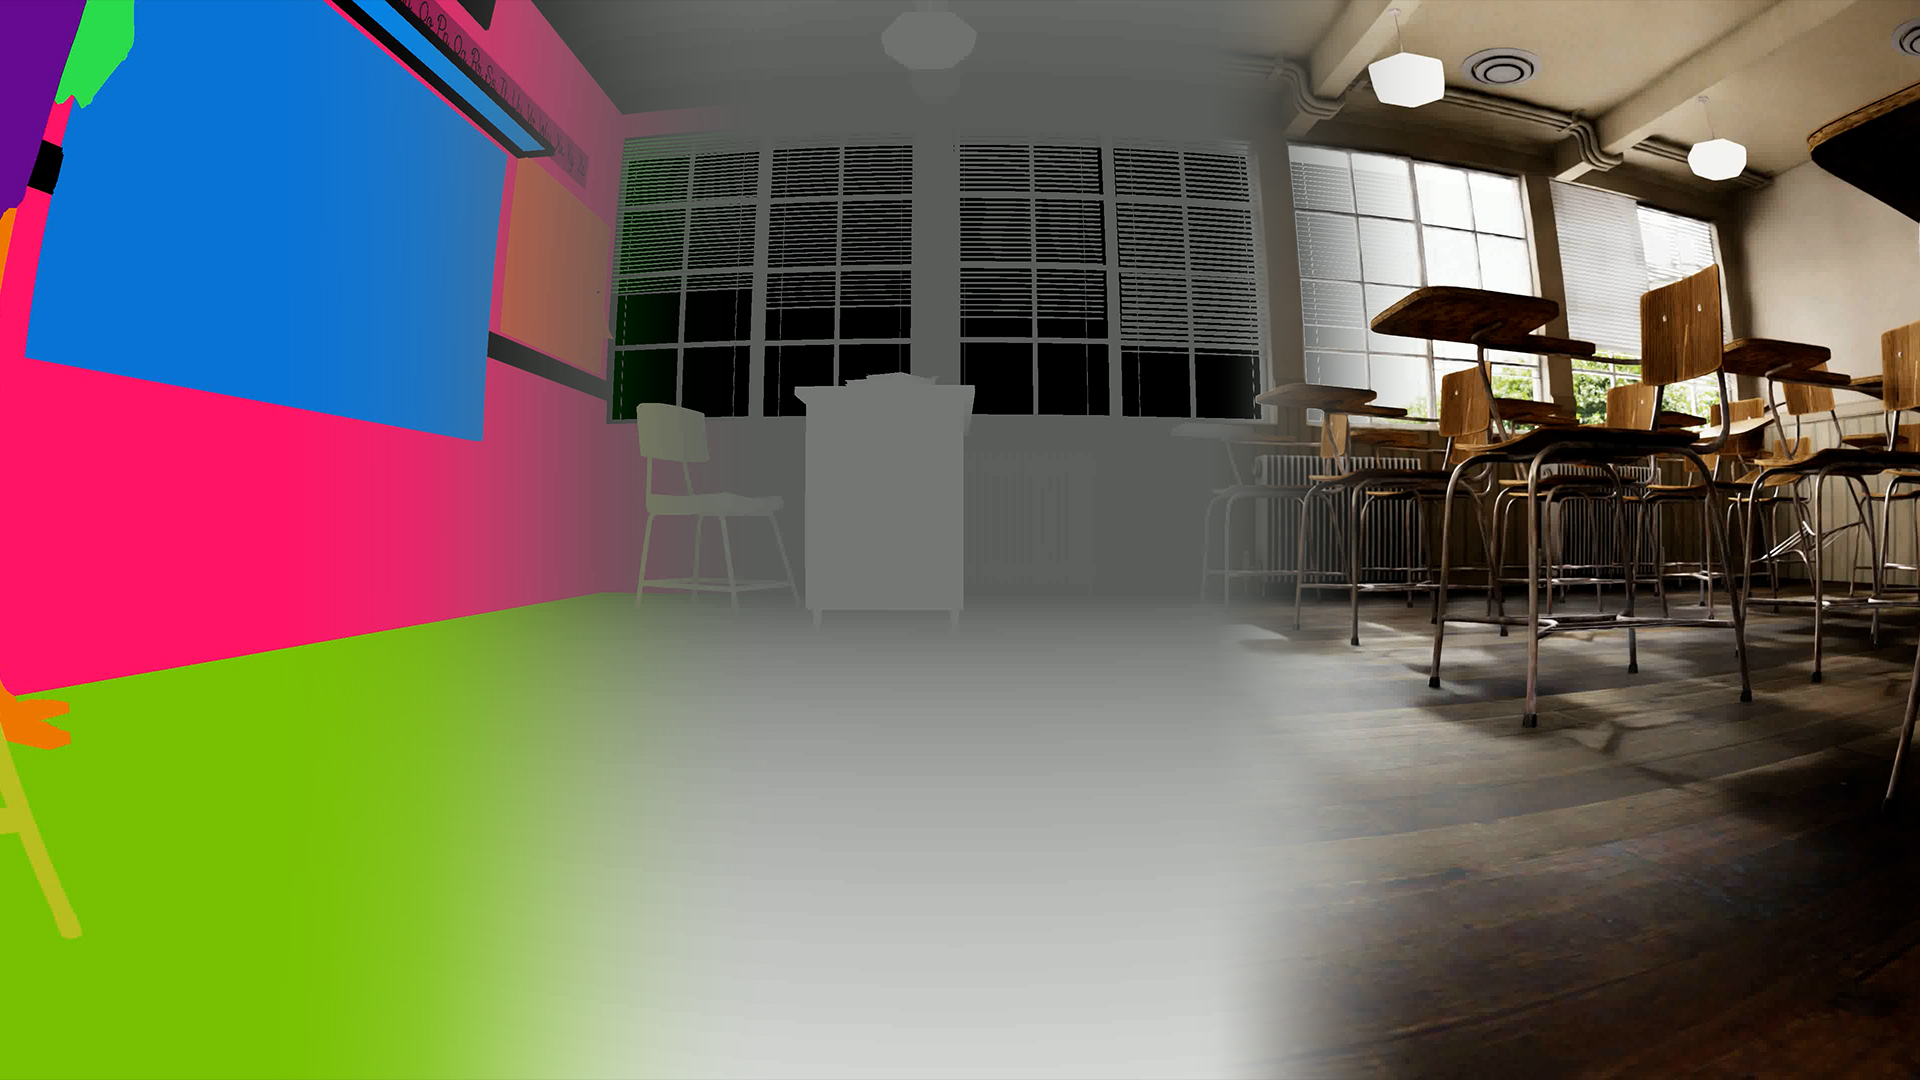
Omniverse Labs
Explore experimental samples and reference patterns for building physical AI workflows with Omniverse libraries, OpenUSD, and agent-callable tools.
Explore Omniverse LabsBlueprints and Agent Workflows
Start from reference workflows that bring together Omniverse libraries, agent skills, and NVIDIA technologies.
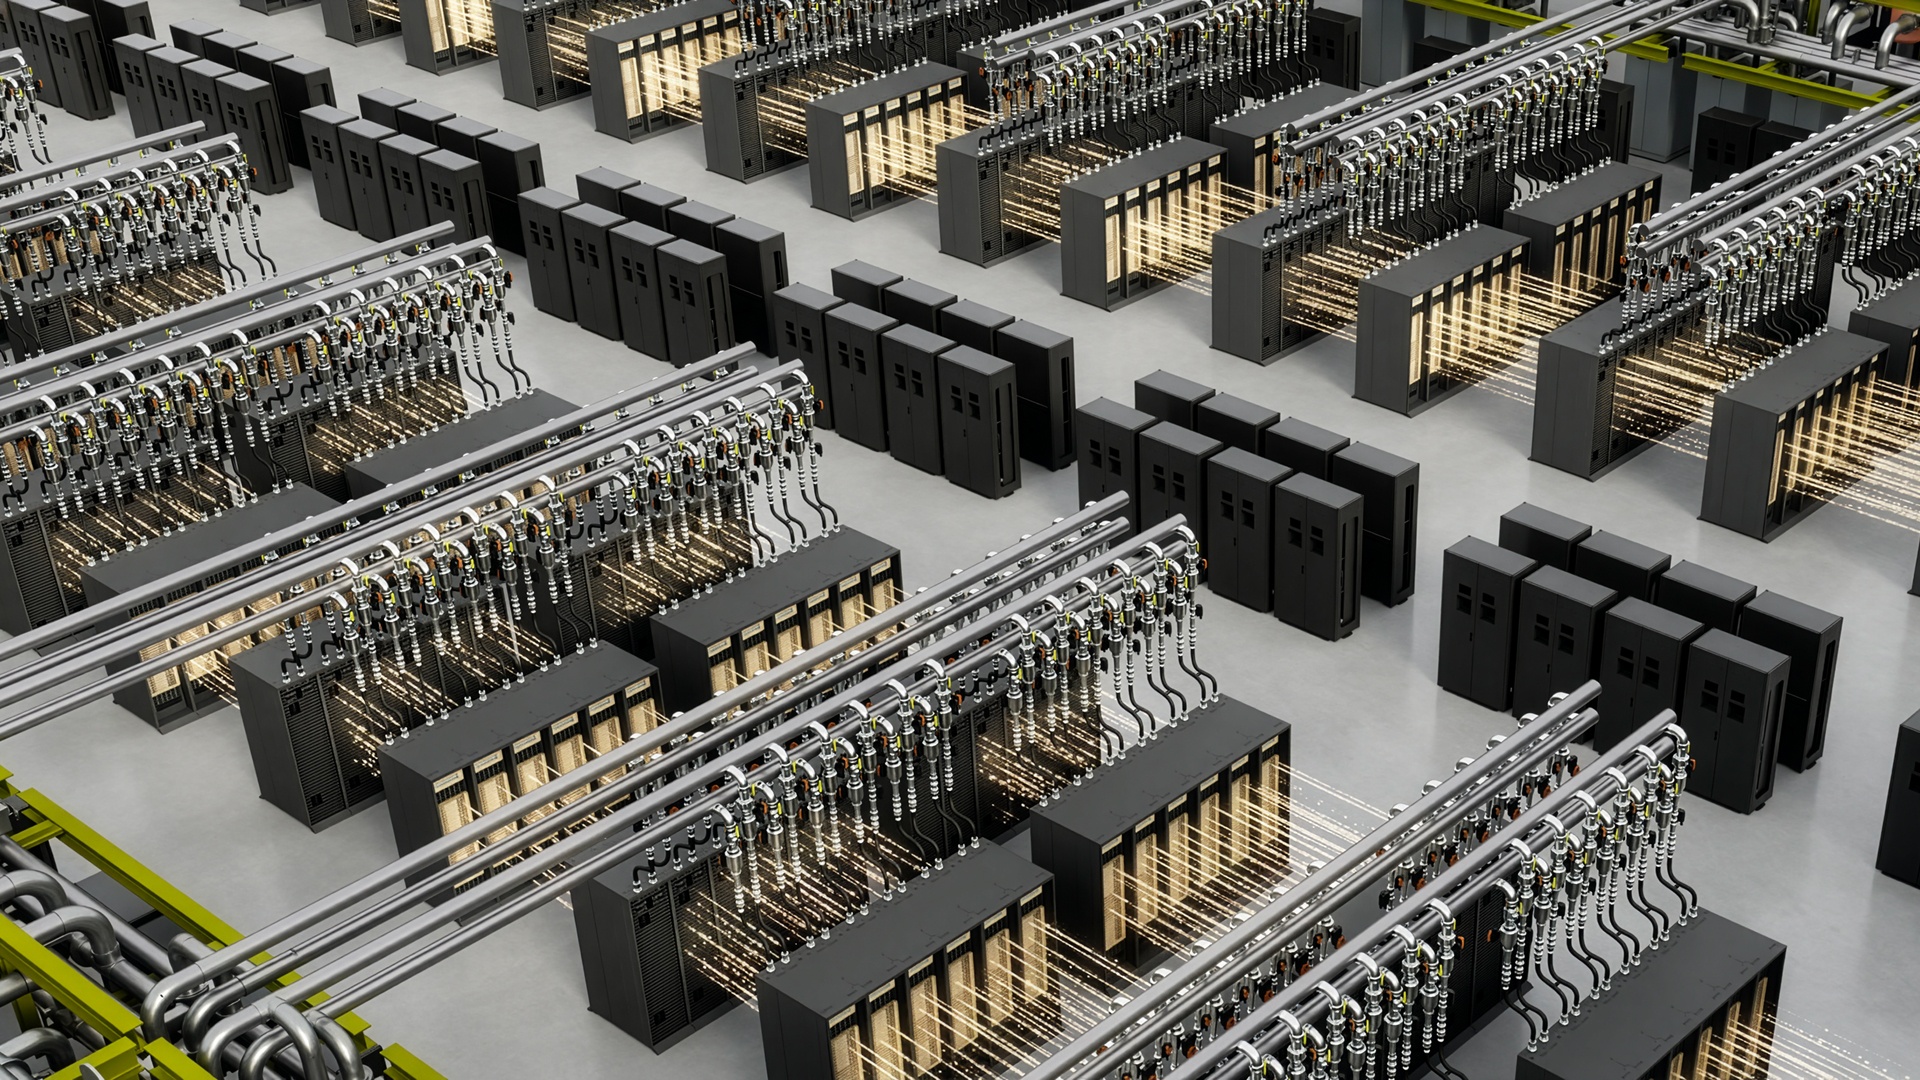
DSX Gigawatt-Scale AI Factories
Optimize design, simulation, and operations of AI factories.
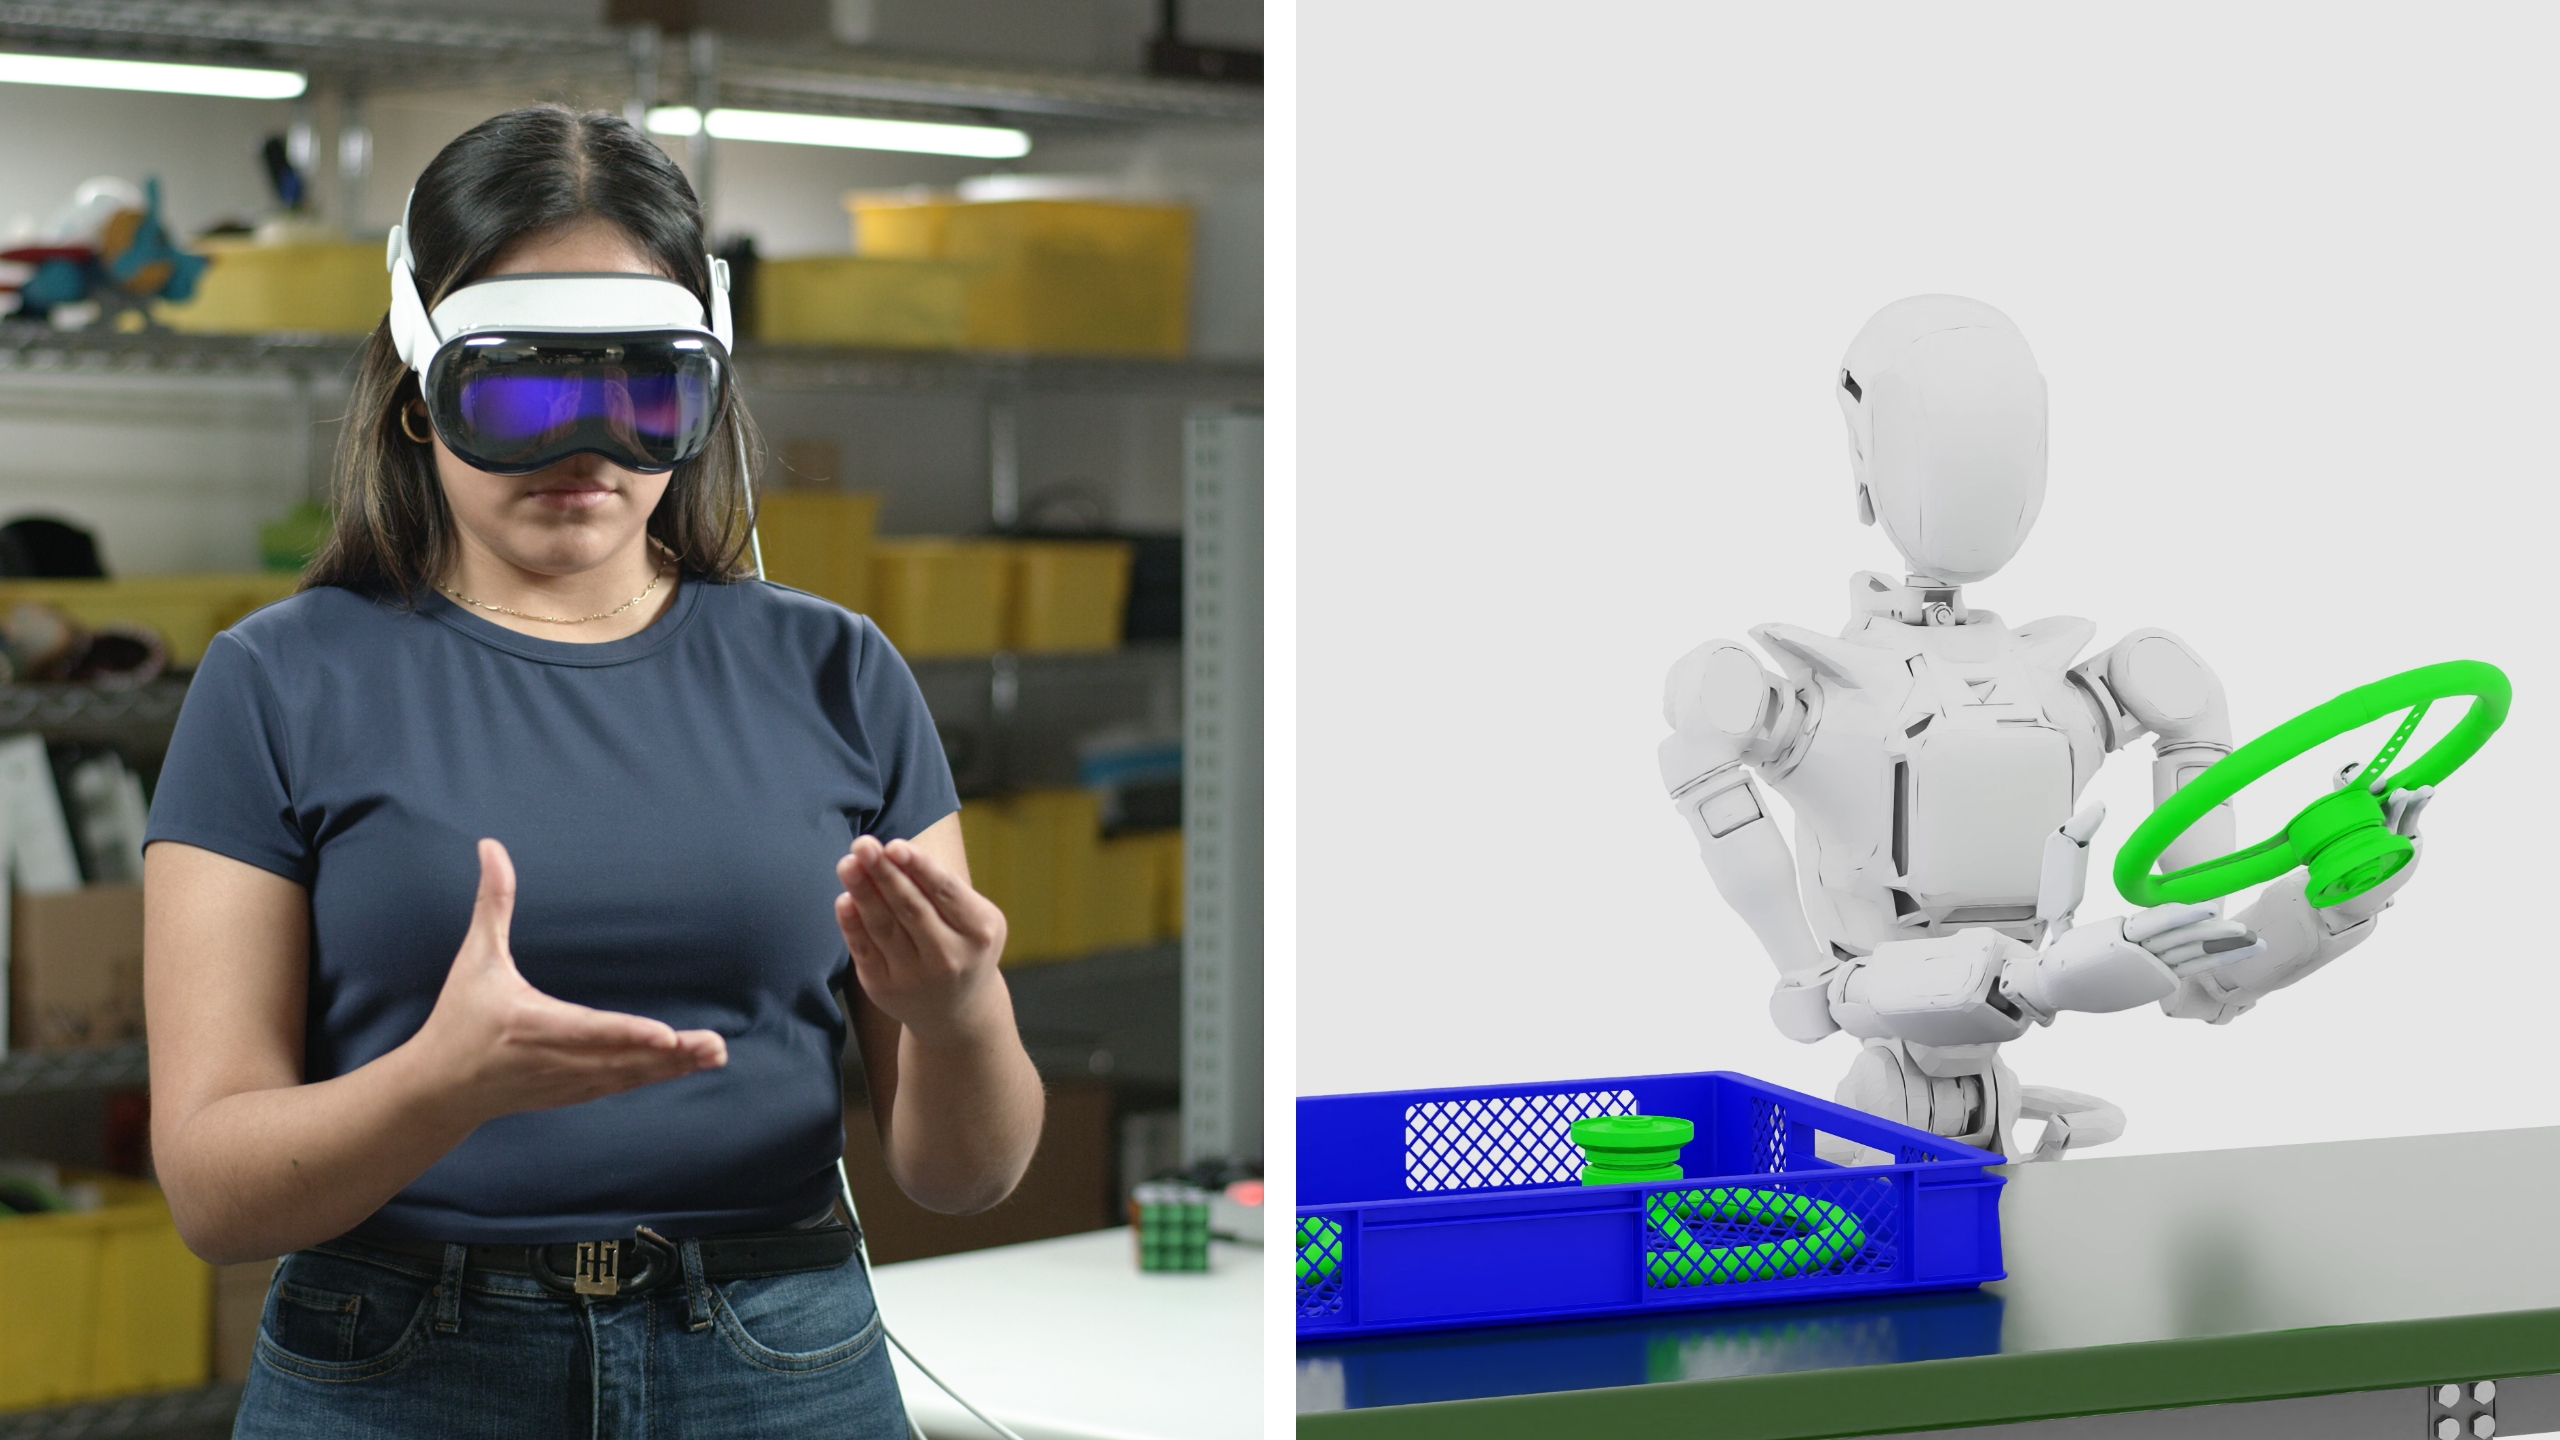
GR00T-Mimic Synthetic Robot Manipulation
Generate exponential synthetic manipulation data for robots.
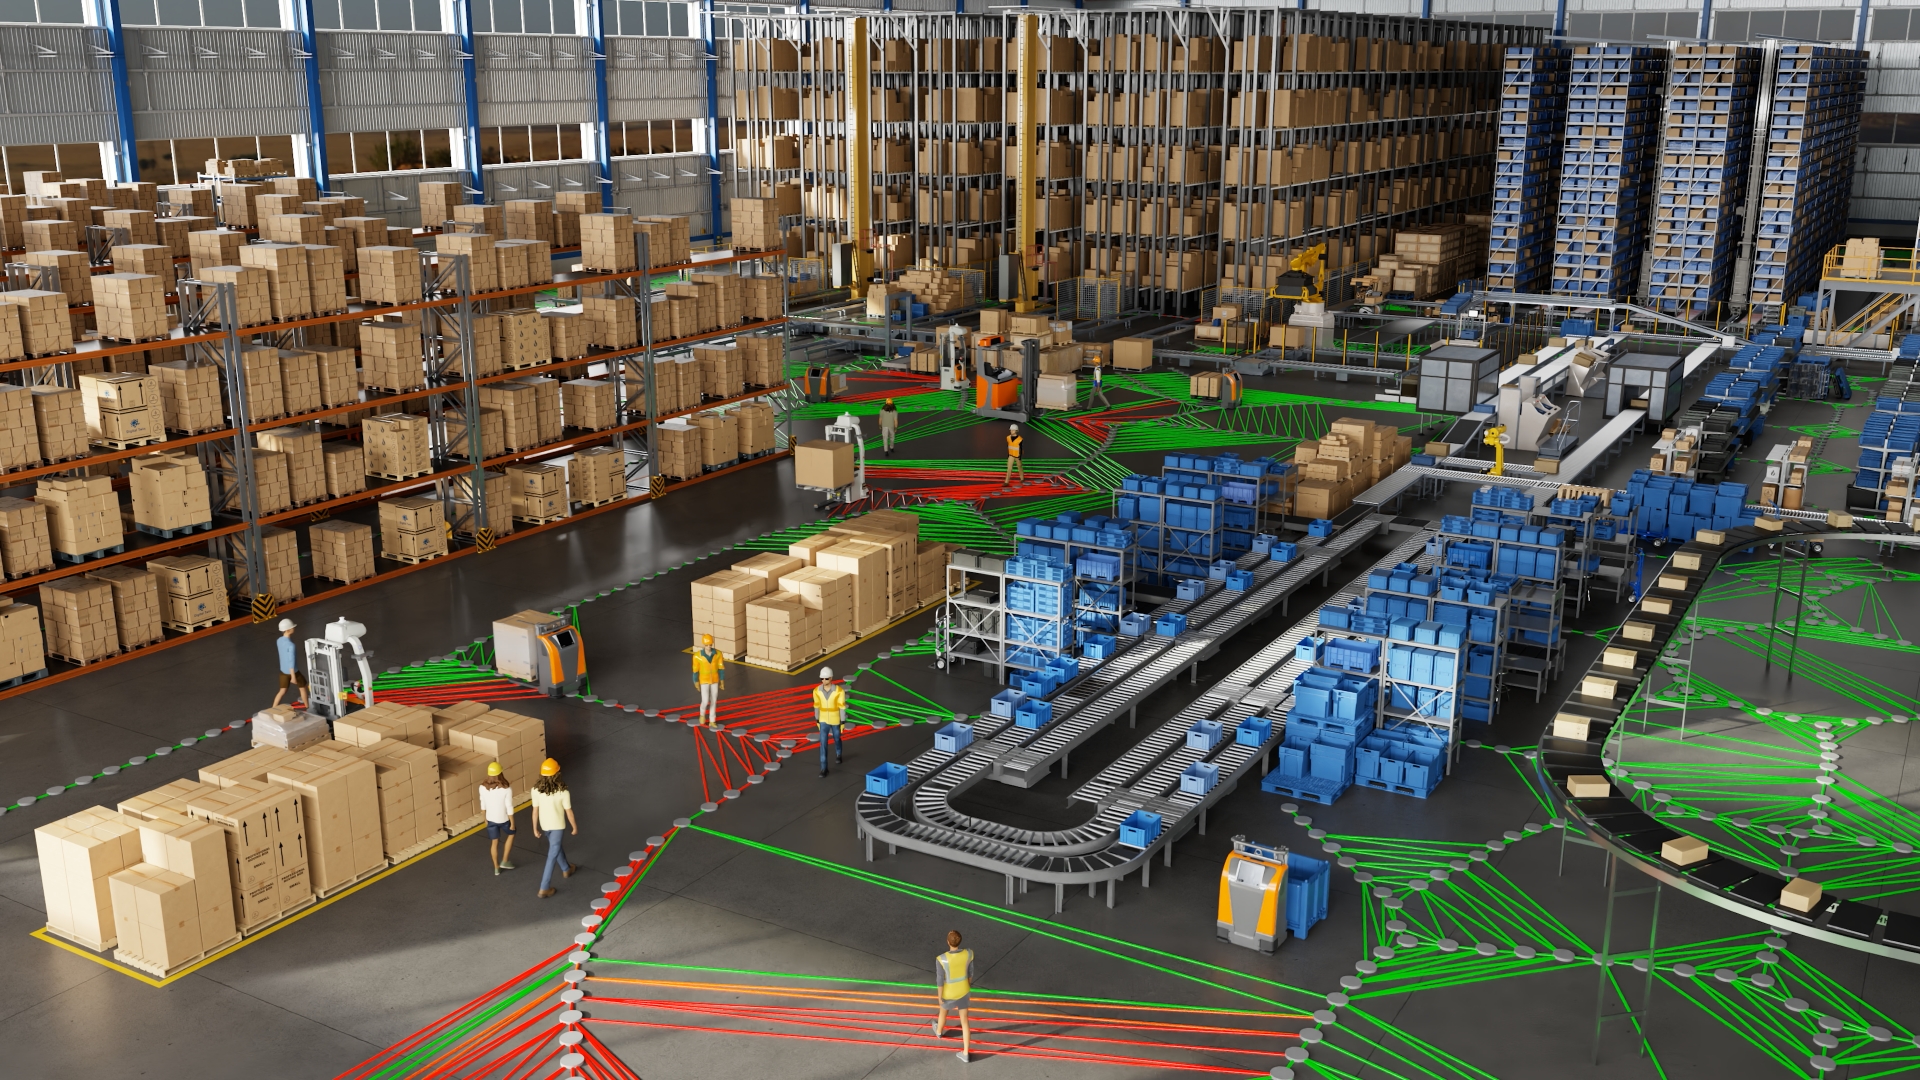
Mega Multi-Robot Fleet Simulation
Scale simulations to test and validate industrial multi-robot fleets before real-world deployment.
Agent Skills for Synthetic Data Generation
Turn coding agents into synthetic data experts for physical AI development.
Digital Twin for Interactive Fluid Simulation
AI-powered virtual wind tunnel for real-time aerodynamic simulation and design.