NVIDIA Isaac Lab
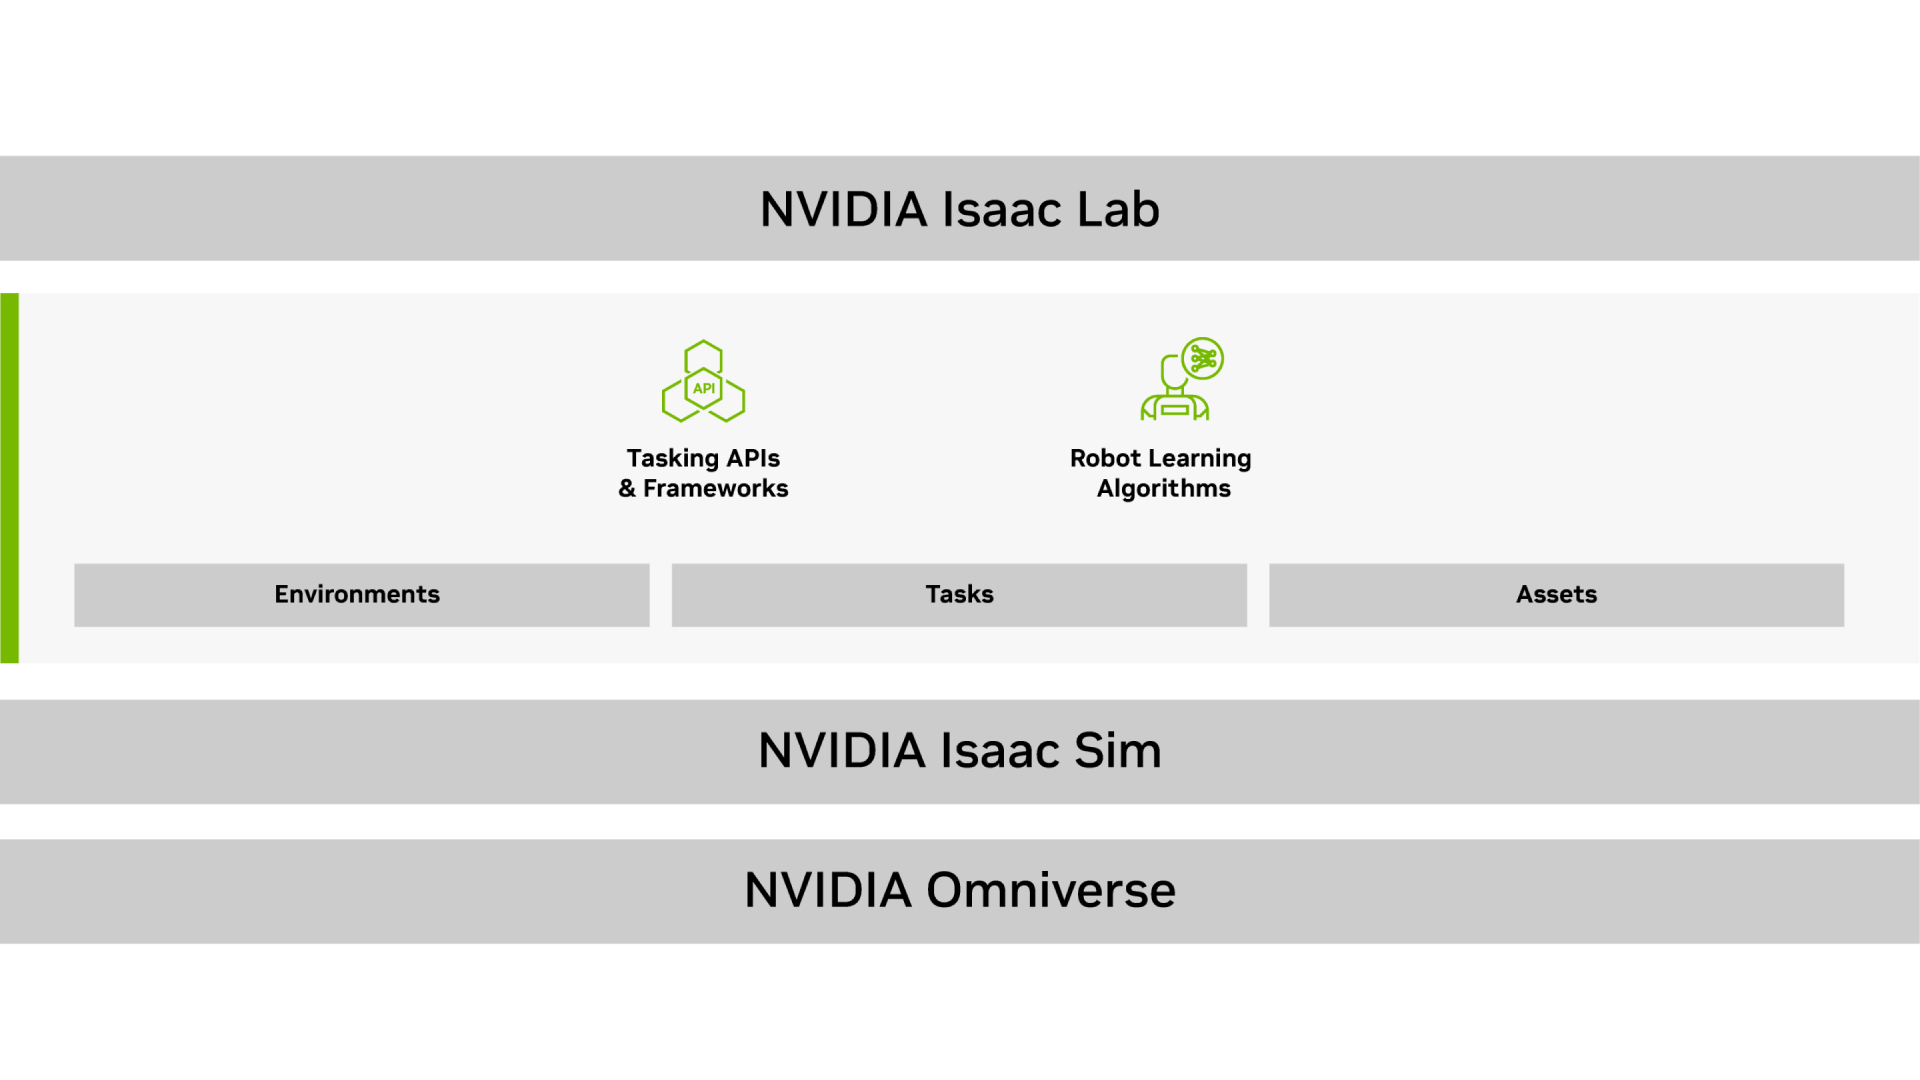
NVIDIA Isaac™ Lab is an open-source, agent-ready modular framework for training and refining robot policies using reinforcement learning and imitation learning.
This unified framework lets you rapidly prototype policies in lightweight simulation environments before deploying to production systems.
How Isaac Lab Works
Isaac Lab’s modular architecture and NVIDIA GPU-based parallelization make it ideal for building robot policies that cover a wide range of embodiments, including humanoid robots, manipulators, and autonomous mobile robots (AMRs).
This gives you a comprehensive framework for robot learning, covering everything from environment setup to policy training. It supports both imitation and reinforcement learning methods. Plus, you can further customize and extend Isaac Lab capabilities with a variety of physics engines, such as Newton, NVIDIA® PhysX®, NVIDIA Warp, and MuJoCo.
Isaac Lab is also the foundational robot learning framework of the NVIDIA Isaac GR00T platform.
Introductory Resources
Isaac Lab Whitepaper
See how the combination of advanced simulation capabilities and data center scale execution unlock breakthroughs in robotics research.
NVIDIA Isaac Lab-Arena
Built on Isaac Lab, Isaac Lab-Arena is an open-source framework for scalable policy evaluation in simulation.
Isaac Lab Courses
Explore our reference workflow that packages supported models, libraries, frameworks, and a task into a single reproducible workflow for a humanoid robot.
Isaac Lab Office Hours
Stay informed with our recurring office hours that cover in-depth topics with experts answering questions about Isaac Lab.
Key Features
Flexible Simulation Backends
Choose the physics, rendering, and visualization backends that best fit your robot learning workload. Train and evaluate policies across simulation backends to build robustness for real-world transfer.
Richer Physics with Newton
Train complex robot skills with Newton. Mix and couple MJWarp, MPM, VBD, and Kamino solvers to simulate articulated rigid bodies, particles, deformables, and closed-chain mechanisms.
Scale Training Anywhere
Scale training from a single GPU to an entire cluster. Massively parallel simulation supports demanding perception-in-the-loop workloads and diverse experiences for more generalizable robot skills.
RL Post-training for Robot Foundation Models
Refine pretrained robot foundation models such as Isaac GR00T with Isaac RL Post Training (RLPT). Use reinforcement learning and parallel simulation to practice at scale and improve existing skills.
Multiple Rendering Options
Choose rendering options from high throughput to photorealism with Newton and OVRTX. Bring reconstructed scenes into simulation with 3D Gaussian rendering or turn simulated depth into photorealistic video with NVIDIA Cosmos 3-Nano Transfer.
Simulation to Deployment
Connect simulation training to real-world deployment with LEAPP. Package a policy’s compute graph and metadata into a portable deployment bundle to bring learned robot skills onto real hardware.
Get Started With Isaac Lab
Download
Get started with the latest version of Isaac Lab by following the installation guides on GitHub.

Tutorials
Access the step-by-step guide to help understand and use various features of the framework.

Start Your Learning Path
Explore advanced concepts in robot learning, gain practical skills, and learn how you can streamline your development processes with Isaac Lab.
Starter Kits
View more tutorials and how-to guides in the documentation.
Accelerate Robot Learning
Choose from reinforcement learning and imitation learning to train AI robots. Easily bring your custom libraries and use the direct agent-environment or hierarchical-manager development workflows.
Enable Perception in the Loop
Tiled rendering reduces rendering time by consolidating input from multiple cameras into a single large image. With a streamlined API for handling vision data, the rendered output directly serves as observational data for simulation learning.
Scale With Multi-GPU and Multi-Node Training
Scale up training of cross-embodied models for complex reinforcement learning environments across multiple GPUs and nodes. Deploy locally and on the cloud (AWS, GCP, Azure, and Alibaba Cloud) by integrating with NVIDIA OSMO.
Accurate High-Fidelity Physics Simulation and Rendering in Omniverse
Tap into the latest GPU-accelerated PhysX version through Isaac Lab, including support for deformables, ensuring quick and accurate physics simulations augmented by domain randomizations.
Isaac Lab Learning Library
Streamline Robot Learning with Whole-Body Control and Enhanced Teleoperation in NVIDIA Isaac Lab 2.3
NVIDIA Isaac Lab
The latest version of Isaac Lab 2.3, in early developer preview, improves humanoid robot capabilities with advanced whole-body control, enhanced imitation learning, and better locomotion.
Quadruped Robot Locomotion and Multiphysics Simulation Using Newton in NVIDIA Isaac Lab
NVIDIA Isaac Lab
Walks through how to train a quadruped robot to move from one point to another and how to set up a multiphysics simulation with an industrial manipulator to fold clothes. This tutorial uses Newton within NVIDIA Isaac Lab.
Ecosystem
Our industry partners and collaborators are integrating NVIDIA Isaac Lab-Arena into their platforms and solutions.


More Resources

Latest Isaac Lab News
Get started with NVIDIA Isaac Lab today.
FAQs
The Isaac Lab framework is open-sourced under the BSD-3-Clause license.
Isaac Sim™ is a comprehensive robotics simulation platform built on NVIDIA Omniverse that provides high-fidelity simulation with advanced physics and photorealistic rendering. It focuses on synthetic data generation (SDG) and testing and validation (SIL/HIL) and is a reference template for custom robotics simulators.
In contrast, Isaac Lab is a lightweight, open-source framework built on top of Isaac Sim, specifically optimized for robot learning workflows and designed to simplify common tasks in robotics research like reinforcement learning, imitation learning, and motion planning.
If you’re an existing NVIDIA Isaac Gym (predecessor of Isaac Lab) user, we recommend migrating to Isaac Lab to ensure you have access to the latest advancements in robot learning and a powerful development environment to accelerate your robot training efforts. Check out the migration guide from Isaac Gym environments to Isaac Lab.
Yes, Isaac Lab and MuJoCo are complementary. MuJoCo's ease of use and lightweight design allow for rapid prototyping and deployment of policies and Isaac Lab can complement it when you want to create more complex scenes, scaling massively parallel environments with GPUs and high-fidelity sensor simulations with RTX rendering. NVIDIA and MuJoCo are actively exploring advancing technical collaborations, stay tuned for future announcements.