NVIDIA Isaac Capture
NVIDIA Isaac™ Capture unifies the Isaac Teleop and ego pipeline frameworks, as well as shared tools for device integration, retargeting, and data collection for robot learning.
How Isaac Capture Works
NVIDIA Isaac Capture brings robot teleoperation and egocentric human-data capture into one repository. Isaac Teleop connects input devices to simulated or physical robots: device plug-ins collect tracking data, retargeters translate human motion into robot actions, and shared data utilities support recording, playback, and downstream dataset workflows.
The ego pipeline, which includes EgoHand and EgoPost, supports the egocentric workflow—from video capture to post-processing and hand-motion reconstruction. Both workflows build on a shared core of device plug-ins, retargeters, and data utilities, so you can extend your collection setup without rebuilding each integration.
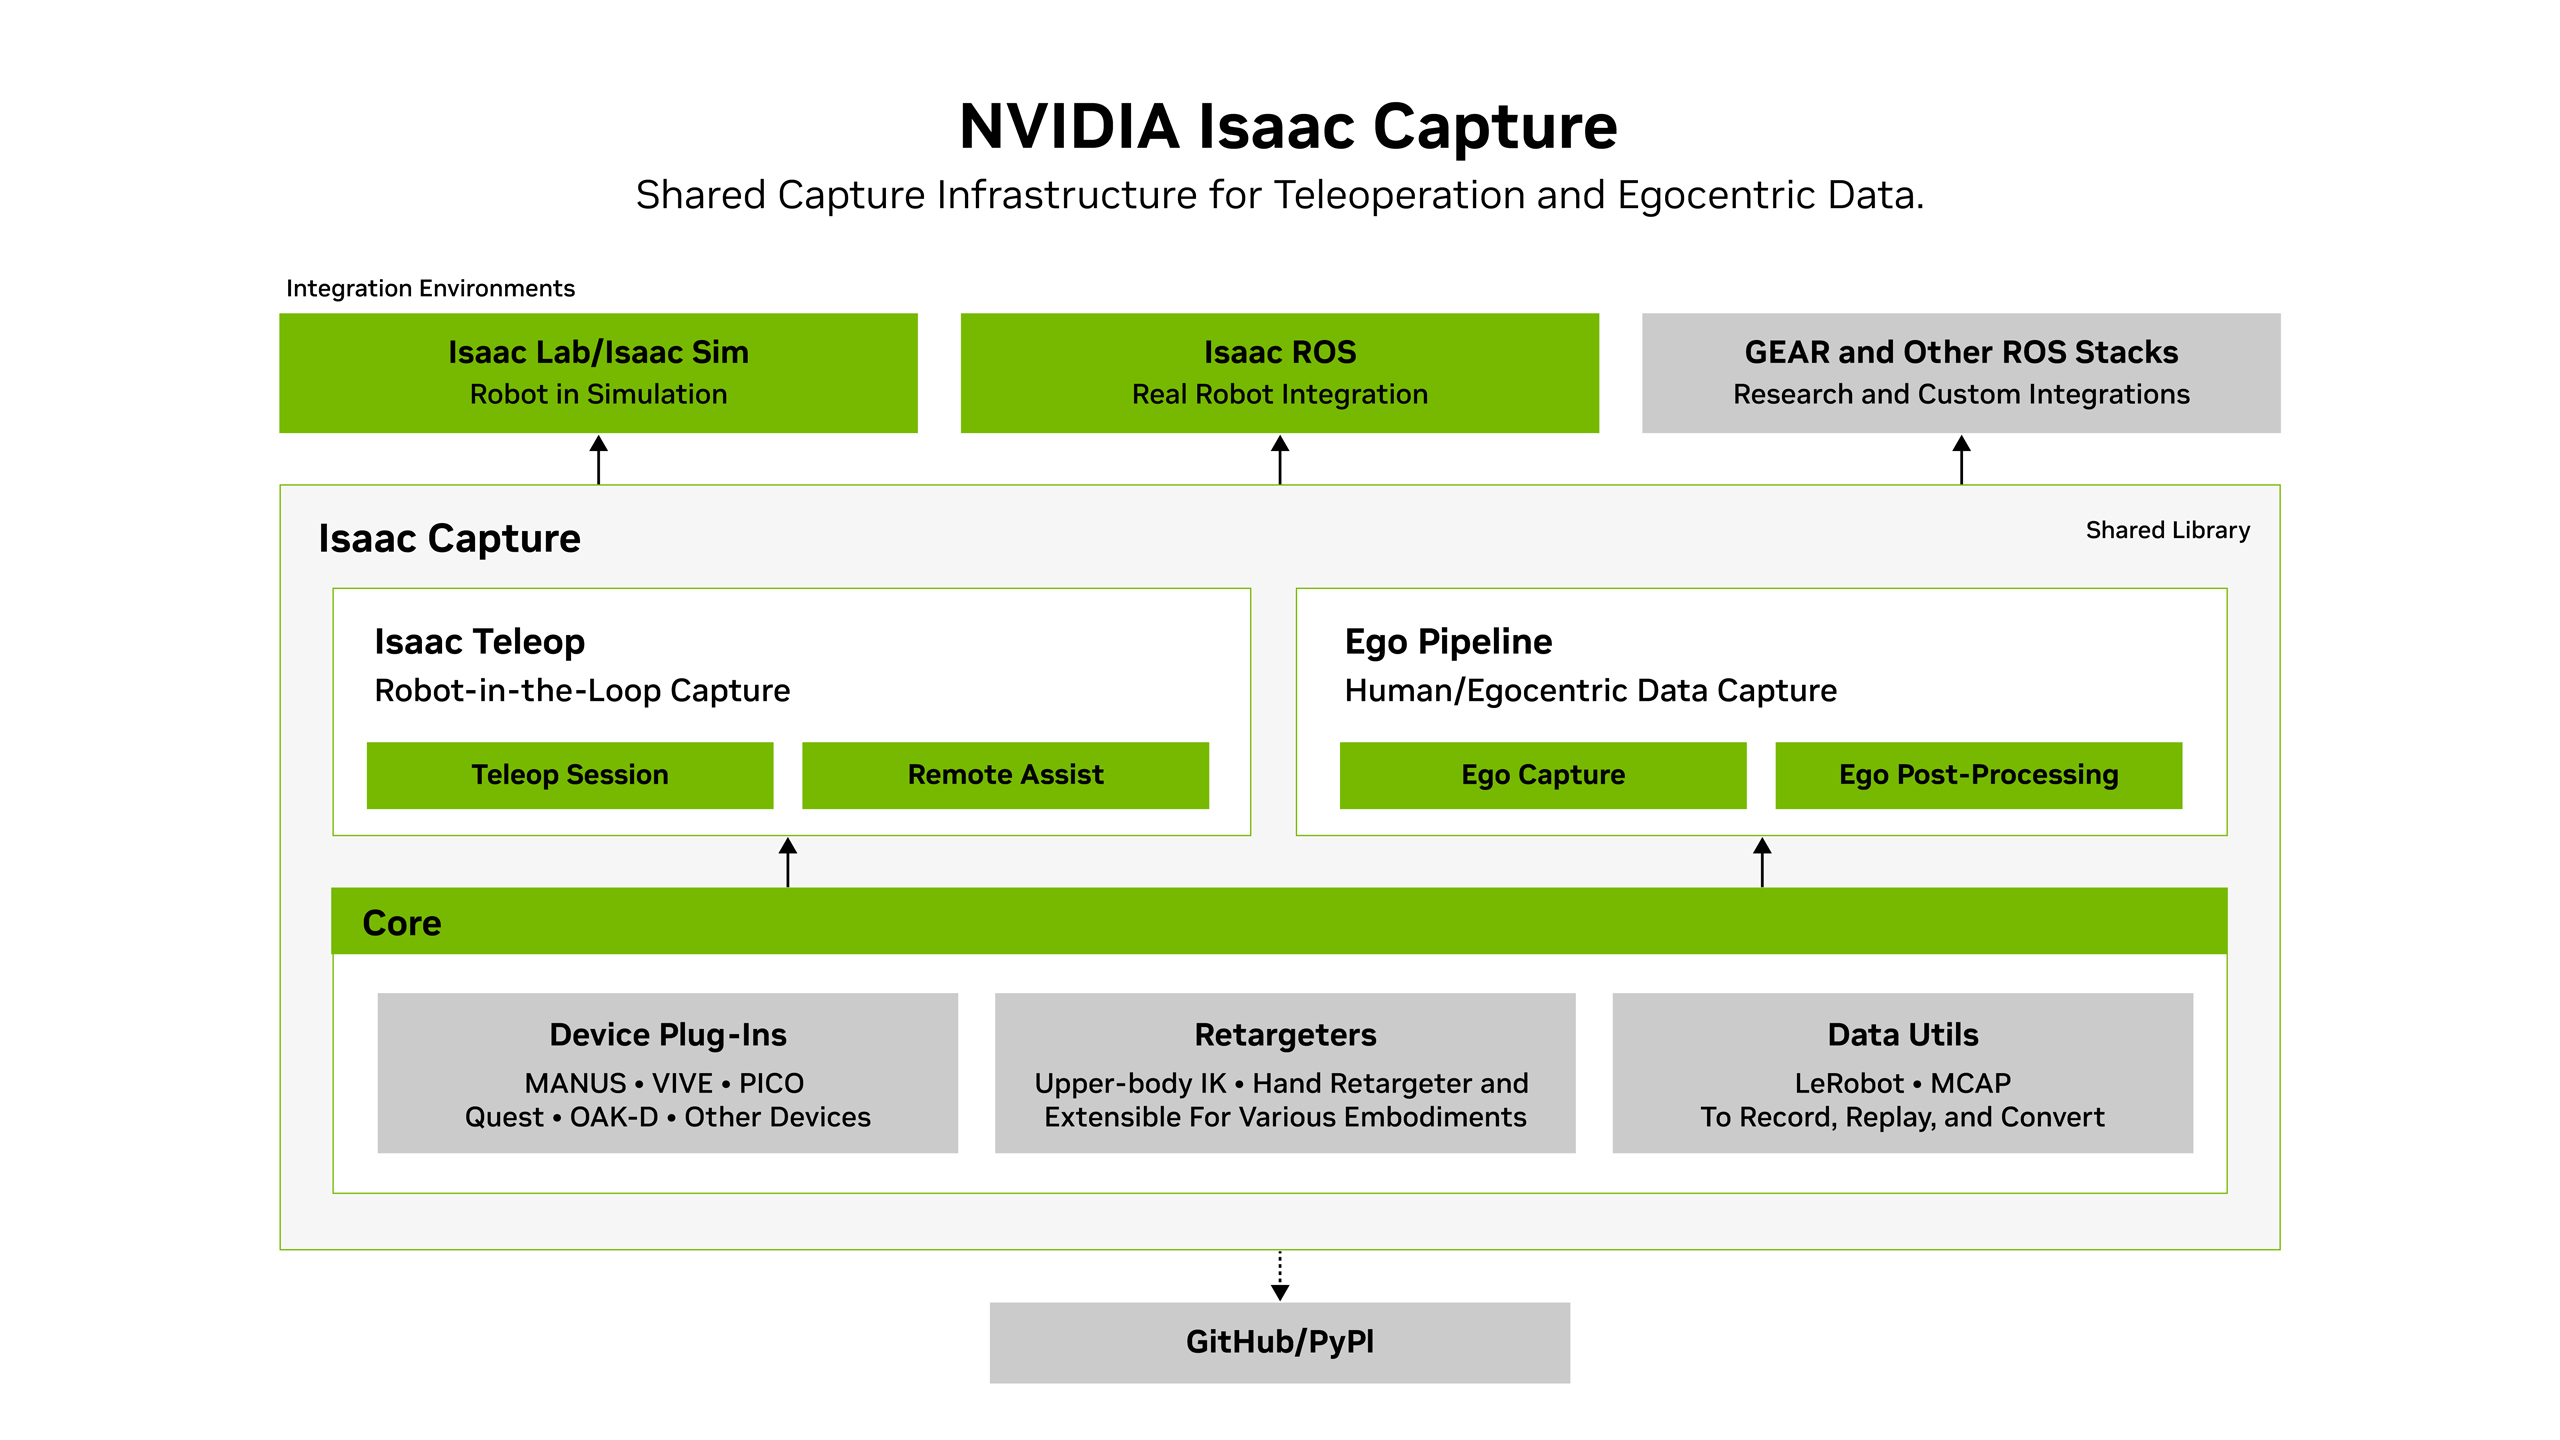
Isaac Teleop Architecture
Learn about the shared interfaces that connect devices, robot actions, and recorded data.
Your First Teleop Session
Connect an XR headset and follow the quick start to process live tracking data.
EgoHand Reconstruction
Learn about video capture and post-processing for reconstructing hand and camera motion.
Device Integration
Connect supported devices or extend the framework with your own device plug-in.
Customize Retargeting
Map tracking inputs to robot-specific actions with a configurable retargeting pipeline.
Record and Replay Data
Use MCAP recording and playback to inspect and reuse captured device streams.
Collect Data With LeRobot
Follow the SO-101 workflow to connect teleoperation with robot demonstration datasets.
Visualize Operator Feedback
Explore Televiz for viewing camera and sensor feeds during teleoperation.
Get Started With Isaac Capture: Choose a Workflow
Collect robot demonstrations with Isaac Teleop, explore egocentric processing with EgoHand, or customize the shared core for your devices and robots.

Isaac Teleop
Control robots in simulation and the real world with supported XR headsets, gloves, and trackers.
Start Teleoperating
EgoHand
Experience egocentric video capture and hand-motion reconstruction for human-demonstration datasets.
Explore Hand Reconstruction
Shared Core
Extend device plug-ins, configure retargeters, and reuse data utilities across your capture workflows.
Explore the ArchitectureStarter Kits
Start with example workflows and adapt them to your devices, robots, and data collection goals.
Robot Teleoperation
Connect an XR headset, configure a teleoperation session, and map live human inputs to robot actions. Use the same framework across supported simulation and real-robot integrations.
Egocentric Human Data
Capture human demonstrations and explore EgoHand post-processing for hand-motion reconstruction. Review the reconstruction guide for setup, model dependencies, and applicable licenses.
LeRobot Data Collection
Connect Isaac Teleop to LeRobot for collecting robot demonstrations. Start with the SO-101 example and follow the guides for your simulation or hardware setup.
More Resources


Get started with Isaac Capture today.