NVIDIA Isaac ROS
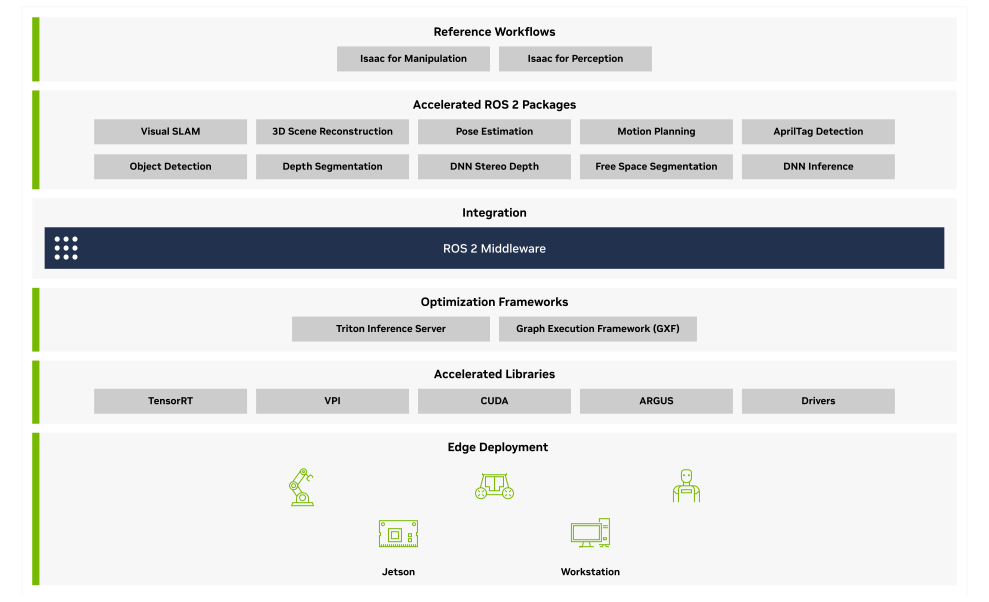
NVIDIA Isaac™ ROS is an agent-friendly, open source software foundation for building AI-powered robots with ROS 2. Built on NVIDIA’s upstream contributions to the ROS ecosystem, it combines accelerated computing, optimized robotics software, AI models, workflows, and deployment tools to help developers build, deploy, and scale production-ready robots faster.
How NVIDIA Isaac ROS Works
Isaac ROS connects the open ROS ecosystem with NVIDIA Isaac agent skills, accelerated computing, and physical AI technologies. Developers can continue using familiar ROS 2 tools while adding production-ready packages, models, libraries, and deployment workflows optimized for NVIDIA platforms—from prototyping in NVIDIA Isaac Sim™ to deployment on NVIDIA Jetson™.
Quick Start Guide
Learn what you need to get started and how to set up using the Isaac ROS suite to tap into the power of NVIDIA acceleration on NVIDIA Jetson.
Introductory Talk
Isaac ROS offers modular packages for robotic perception and easy integration into existing ROS 2-based applications. This talk covers Isaac ROS GEMs and how to use multiple GEMs in your robotics pipeline.
Use an AI Agent to CUDA-Accelerate a ROS 2 Node
Learn how to use a dedicated AI agent skill to upgrade an existing NVIDIA CUDA™-accelerated ROS 2 node for efficient memory transport.
Key Features
ROS is a trademark of Open Robotics
Open Ecosystem
Built on ROS
Built on NVIDIA’s upstream contributions to ROS, Isaac ROS remains compatible with open ROS standards and gives developers access to NVIDIA-accelerated computing, models, and libraries without requiring a different development framework.
Hardware Acceleration
NVIDIA Isaac Transport for ROS
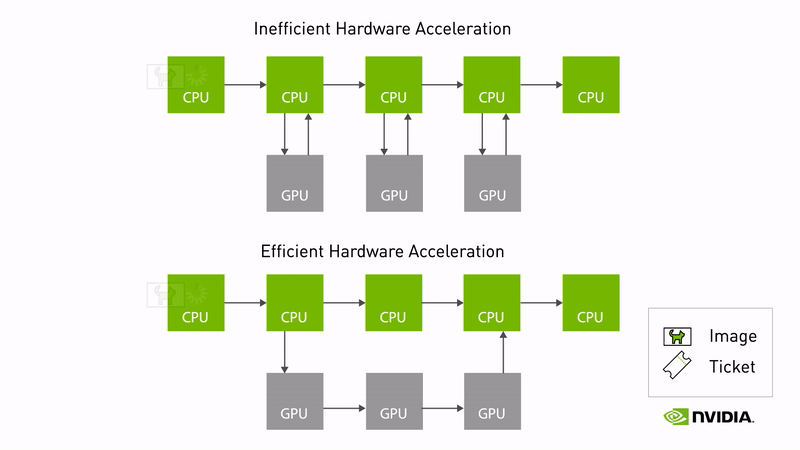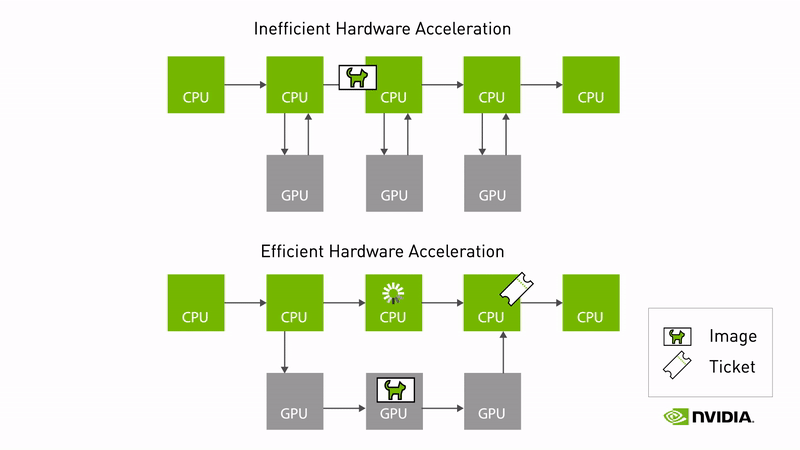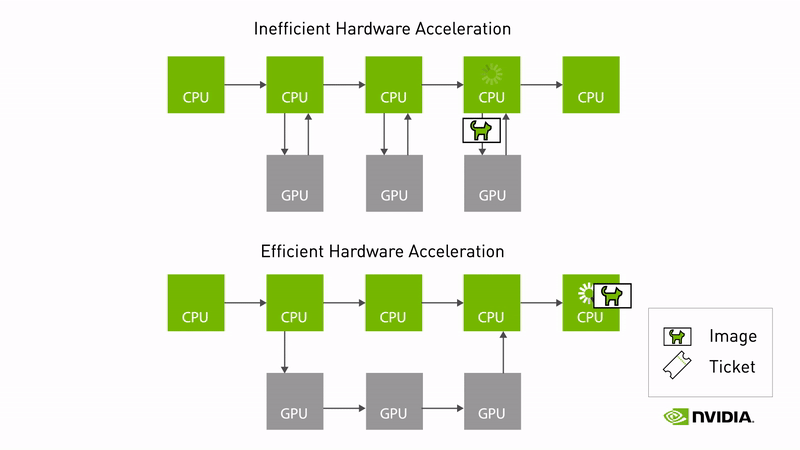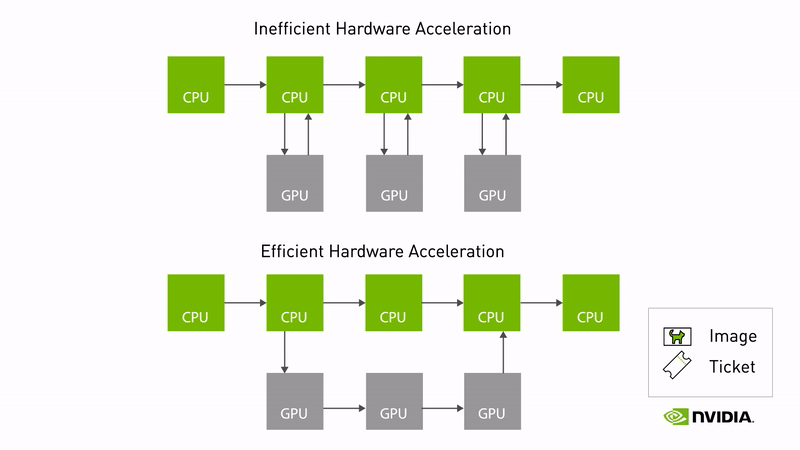
NVIDIA Isaac Transport for ROS (NITROS) accelerates ROS 2 processing pipelines while preserving portability and interoperability. It helps applications take fuller advantage of NVIDIA GPU acceleration for higher throughput and more efficient use of computing resources across the ROS 2 graph. NITROS is now natively available in ROS 2 Lyrical for all ROS 2 developers through the official CUDA backend plugin.
Download NVIDIA Isaac Transportfor ROS (Github)
Build AI Robots Faster
Deploy perception, localization, mapping, manipulation, teleoperation, and AI inference using production-ready ROS packages optimized for NVIDIA platforms.
Reduce Integration Complexity
Use a unified workflow from simulation and development through deployment, reducing the effort required to assemble and maintain disconnected components.
Extend Robots With Physical AI
Connect ROS applications to NVIDIA’s broader physical AI platform and adopt new models and AI capabilities while continuing to use familiar ROS tools and open standards.
Getting Started on NVIDIA Isaac ROS

System Setup
Tap into NVIDIA-accelerated libraries and AI models to speed up your AI robot workflows. Check your system requirements and set up your system.
Get Started
Plug-and-Play ROS Packages
Read through the Isaac ROS concepts and easily move to production with a selection of advanced packages.
Isaac ROS Packages
Deployment on the Edge With Partner Kits
NVIDIA Jetson is the agentic-ready platform for physical AI, combining accelerated computing, a broad partner ecosystem, and power-efficient design to help you build and deploy Isaac ROS applications faster
NVIDIA Isaac for Manipulation
CUDA-accelerated libraries and AI models give you a faster, easier way to develop AI-powered robotic arms that can seamlessly perceive, understand, and interact with their environments.
Learn More About Isaac for ManipulationNVIDIA Isaac for Mobility
Accelerate the development of advanced autonomous mobile robots (AMRs) that can perceive, localize, and operate in unstructured environments like warehouses or factories.
Learn More About Isaac for MobilityHigh-Performance Perception With NITROS Pipelines
ROS 2 graphs built with NITROS-based Isaac ROS packages deliver accelerated performance on NVIDIA platforms without sacrificing portability or interoperability. Explore benchmark results across Jetson, NVIDIA DGX Spark™, and x86 systems.
Node |
Input Size |
AGX Thor |
AGX Thor |
DGX Spark |
x86_64 w/ RTX 5090 |
|---|---|---|---|---|---|
AprilTag Node |
720p |
355.8 fps 2.75 ms @ 30 Hz |
192.2 fps 5.13 ms @ 30 Hz |
464.3 fps 2.34 ms @ 30 Hz |
517.5 fps 4.42 ms @ 30 Hz |
NVIDIA TensorRT™ Node PeopleSemSegNet |
544p |
680.8 fps 1.33 ms @ 30 Hz |
495.3 fps 1.45 ms @ 30 Hz |
1021.2 fps 0.98 ms @ 30 Hz |
1404.7 fps 1.07 ms @ 30 Hz |
Triton Node PeopleSemSegNet |
544p |
187.4 fps 5.32 ms @ 30 Hz |
187.2 fps 5.62 ms @ 30 Hz |
246.6 fps 4.61 ms @ 30 Hz |
1105.8 fps 1.48 ms @ 30 Hz |
Resize |
1200pp |
2663.6 fps 0.33 ms @ 30 Hz |
2811.1 fps 0.37 ms @ 30 Hz |
2439.5 fps 0.22 ms @ 30 Hz |
819.8 fps 0.22 ms @ 30 Hz |
H.264 Decoder Node |
1080p |
458.3 fps 1.88 ms @ 30 Hz |
204.7 fps 8.33 ms @ 30 Hz |
349.3 fps 2.12 ms @ 30 Hz |
738.3 fps 1.89 ms @ 30 Hz |
H.264 Encoder Node I-frame Support |
1080p |
769.2 fps 1.97 ms @ 30 Hz |
398.1 fps 11.53 ms @ 30 Hz |
895.8 fps 2.19 ms @ 30 Hz |
1082.4 fps 1.69 ms @ 30 Hz |
H.264 Encoder Node P-frame Support |
1080p |
779.7 fps 1.93 ms @ 30 Hz |
459.9 fps 11.53 ms @ 30 Hz |
880.5 fps 2.53 ms @ 30 Hz |
1114.0 fps 1.59 ms @ 30 Hz |
FoundationPose Tracking |
720p |
479.6 fps 2.96 ms @ 30 Hz |
197.5 fps 3.68 ms @ 30 Hz |
438.0 fps 2.80 ms @ 30 Hz |
617.5 fps 3.22 ms @ 30 Hz |
Starter Kits
Start with validated Isaac ROS packages, tutorials, and reference implementations for localization, mapping, scene reconstruction, pose estimation, motion planning, and simulation. These building blocks help teams accelerate development without assembling robotics applications from scratch.
Localization and Mapping
Isaac ROS Visual SLAM provides a high-performance, best-in-class ROS 2 package for VSLAM (visual simultaneous localization and mapping).
3D Scene Reconstruction
Isaac ROS nvBlox uses RGB-D and/or lidar data to create a dense 3D map, including unforeseen obstacles, to generate a temporal costmap for navigation.
Depth Estimation
FoundationStereo is a foundation model for stereo depth estimation across diverse environments and camera configurations. It generates disparity maps from stereo image pairs, enabling depth estimation and point-cloud generation.
Pose Estimation and Tracking
NVIDIA’s FoundationPose is a state-of-the-art foundation model for 6D pose estimation and tracking of novel objects.
Motion Planning
Isaac ROS cuMotion is an NVIDIA CUDA-accelerated library for solving robot motion planning problems at scale by running multiple trajectory optimizations simultaneously to return the best solution.
Testing and Validation in Simulation
Virtually train, test, and validate robotics systems using NVIDIA Isaac Sim and NVIDIA Isaac Lab.
Isaac ROS Learning Library
More Resources

Get Started
Build, deploy, and scale AI-powered robots faster with the agent-friendly, open source NVIDIA Isaac ROS software foundation.